# Industrial Robot Arm
> A stylized industrial robot arm on a bolted pedestal with a fully rigged joint chain: base (yaw), shoulder, elbow and wrist groups pivot exactly at their joint axes, ending in a parallel gripper group with two sliding fingers. Includes motor housings, a cable hose, hazard stripes and a status light. Pose it with the turn, shoulder, elbow and wrist angles — great for factories, labs, sci-fi bases and assembly-line puzzle games.
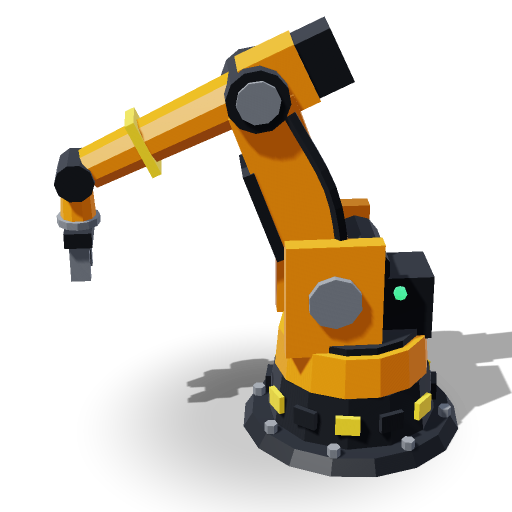
Multi-view sheet (3/4, front, side, top): https://codels.download/m/robot-arm.sheet.png
## Facts
- Category: Sci-Fi › Robots & Drones
- Size (W × H × D): 1.85 × 2.24 × 1.68 m — units are meters, +Y up, front faces +Z
- Origin: center of the base (y = 0)
- Triangles: 1,216 · Meshes: 48 · Materials: 5
- License: CC0-1.0 (Codels built-in)
- Tags: machine, robot, robot-arm, low-poly, stylized, industrial, modern, sci-fi, interior, puzzle, hazard, interactable, prop, metal, emissive, game-ready, mobile-friendly, parametric, color-gray, color-orange, size-medium, poly-low
- Page: https://codels.download/models/robot-arm
## Files
| Format | URL |
|---|---|
| three.js ES module (`createRobotArm()`) | https://codels.download/m/robot-arm.js |
| React Three Fiber component (``) | https://codels.download/m/robot-arm.jsx |
| Instancing module (`createRobotArmInstances(count, place)`, one draw call per material) | https://codels.download/m/robot-arm.instanced.js |
| Standalone HTML demo | https://codels.download/m/robot-arm.html |
| glTF binary | https://codels.download/m/robot-arm.glb |
| glTF binary, Meshopt-compressed (2–3× smaller; GLTFLoader needs `setMeshoptDecoder(MeshoptDecoder)`) | https://codels.download/m/robot-arm.glb?compress=meshopt |
| glTF JSON | https://codels.download/m/robot-arm.gltf |
| OBJ (vertex colors) + MTL | https://codels.download/m/robot-arm.obj · https://codels.download/m/robot-arm.mtl |
| STL | https://codels.download/m/robot-arm.stl |
| CodelSpec JSON | https://codels.download/m/robot-arm.json |
## Parameters
Append them as query parameters to any URL above to get a customized variant (e.g. `?bodyColor=...`).
| Param | Type | Range / options | Default | Current |
|---|---|---|---|---|
| `bodyColor` | color | #rrggbb | #ef8a1f | #ef8a1f |
| `baseTurn` | number | -180 – 180 | -50 | -50 |
| `shoulder` | number | -45 – 60 | 20 | 20 |
| `elbow` | number | 0 – 140 | 95 | 95 |
| `wrist` | number | -120 – 120 | 65 | 65 |
## Parts
- pedestal (group)
- floorPlate (cylinder · dark)
- pedestalBody (cylinder · dark)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- bolt (cylinder · metal)
- hazardTile (box · dark)
- hazardTile (box · warn)
- hazardTile (box · dark)
- hazardTile (box · warn)
- hazardTile (box · dark)
- hazardTile (box · warn)
- hazardTile (box · dark)
- hazardTile (box · warn)
- hazardTile (box · dark)
- hazardTile (box · warn)
- hazardTile (box · dark)
- hazardTile (box · warn)
- base (group)
- turntable (cylinder · body)
- turntableRing (cylinder · dark)
- yokePlate (box · body)
- yokePlate (box · body)
- baseMotor (box · dark)
- statusLight (sphere · glow)
- shoulder (group)
- shoulderJoint (cylinder · dark)
- shoulderCap (cylinder · metal)
- upperArm (box · body)
- upperArmPanel (box · dark)
- shoulderMotor (cylinder · dark)
- cableHose (tube · dark)
- elbow (group)
- elbowJoint (cylinder · dark)
- elbowCap (cylinder · metal)
## How to use
Save the code below as `robot-arm.js`, then:
```js
import { createRobotArm } from './robot-arm.js';
const model = createRobotArm();
scene.add(model);
```
## Code
```js
/**
* Industrial Robot Arm — Codels 3D model library (https://codels.download/models/robot-arm)
* License: CC0-1.0 · Units: meters · Y-up · Front: +Z · Origin: center of the base (y = 0)
* Triangles: 1,216 · Size (W × H × D): 1.85 × 2.24 × 1.68 m
*
* Usage:
* import { createRobotArm } from './robot-arm.js';
*
* const model = createRobotArm();
* model.position.set(0, 0, 0);
* scene.add(model);
*/
import * as THREE from 'three';
const deg = THREE.MathUtils.degToRad;
// Tube along a smooth curve through the given points.
function tube(path, radius, tubularSegments, radialSegments, closed = false) {
const curve = new THREE.CatmullRomCurve3(path.map(([x, y, z]) => new THREE.Vector3(x, y, z)), closed);
return new THREE.TubeGeometry(curve, tubularSegments, radius, radialSegments, closed);
}
export function createRobotArm() {
const root = new THREE.Group();
root.name = 'RobotArm';
// Materials
const bodyMat = new THREE.MeshStandardMaterial({ name: 'body', color: 0xef8a1f, roughness: 0.45, metalness: 0.2, flatShading: true });
const darkMat = new THREE.MeshStandardMaterial({ name: 'dark', color: 0x2f3237, roughness: 0.6, metalness: 0.4, flatShading: true });
const metalMat = new THREE.MeshStandardMaterial({ name: 'metal', color: 0xa6acb4, roughness: 0.3, metalness: 0.8, flatShading: true });
const warnMat = new THREE.MeshStandardMaterial({ name: 'warn', color: 0xe9c23a, roughness: 0.5, flatShading: true });
const glowMat = new THREE.MeshStandardMaterial({ name: 'glow', color: 0x5dff8a, roughness: 0.4, emissive: 0x2eff66, emissiveIntensity: 1.4, flatShading: true });
// Shared geometries
const cylinderGeo = new THREE.CylinderGeometry(0.035, 0.035, 0.05, 6);
const boxGeo = new THREE.BoxGeometry(0.13, 0.1, 0.03);
const boxGeo2 = new THREE.BoxGeometry(0.1, 0.62, 0.5);
const boxGeo3 = new THREE.BoxGeometry(0.05, 0.2, 0.1);
const boxGeo4 = new THREE.BoxGeometry(0.02, 0.12, 0.09);
// Parts
const pedestal = new THREE.Group();
pedestal.name = 'pedestal';
root.add(pedestal);
const floorPlate = new THREE.Mesh(new THREE.CylinderGeometry(0.55, 0.6, 0.08, 16), darkMat);
floorPlate.name = 'floorPlate';
floorPlate.position.set(0, 0.04, 0);
pedestal.add(floorPlate);
const pedestalBody = new THREE.Mesh(new THREE.CylinderGeometry(0.42, 0.46, 0.28, 12), darkMat);
pedestalBody.name = 'pedestalBody';
pedestalBody.position.set(0, 0.22, 0);
pedestal.add(pedestalBody);
const bolt = new THREE.Mesh(cylinderGeo, metalMat);
bolt.name = 'bolt';
bolt.position.set(0.199, 0.105, 0.4804);
pedestal.add(bolt);
const bolt2 = new THREE.Mesh(cylinderGeo, metalMat);
bolt2.name = 'bolt';
bolt2.position.set(0.4804, 0.105, 0.199);
pedestal.add(bolt2);
const bolt3 = new THREE.Mesh(cylinderGeo, metalMat);
bolt3.name = 'bolt';
bolt3.position.set(0.4804, 0.105, -0.199);
pedestal.add(bolt3);
const bolt4 = new THREE.Mesh(cylinderGeo, metalMat);
bolt4.name = 'bolt';
bolt4.position.set(0.199, 0.105, -0.4804);
pedestal.add(bolt4);
const bolt5 = new THREE.Mesh(cylinderGeo, metalMat);
bolt5.name = 'bolt';
bolt5.position.set(-0.199, 0.105, -0.4804);
pedestal.add(bolt5);
const bolt6 = new THREE.Mesh(cylinderGeo, metalMat);
bolt6.name = 'bolt';
bolt6.position.set(-0.4804, 0.105, -0.199);
pedestal.add(bolt6);
const bolt7 = new THREE.Mesh(cylinderGeo, metalMat);
bolt7.name = 'bolt';
bolt7.position.set(-0.4804, 0.105, 0.199);
pedestal.add(bolt7);
const bolt8 = new THREE.Mesh(cylinderGeo, metalMat);
bolt8.name = 'bolt';
bolt8.position.set(-0.199, 0.105, 0.4804);
pedestal.add(bolt8);
const hazardTile = new THREE.Mesh(boxGeo, darkMat);
hazardTile.name = 'hazardTile';
hazardTile.position.set(0, 0.22, 0.45);
pedestal.add(hazardTile);
const hazardTile2 = new THREE.Mesh(boxGeo, warnMat);
hazardTile2.name = 'hazardTile';
hazardTile2.position.set(0.225, 0.22, 0.3897);
hazardTile2.rotation.set(0, deg(30), 0);
pedestal.add(hazardTile2);
const hazardTile3 = new THREE.Mesh(boxGeo, darkMat);
hazardTile3.name = 'hazardTile';
hazardTile3.position.set(0.3897, 0.22, 0.225);
hazardTile3.rotation.set(0, deg(60), 0);
pedestal.add(hazardTile3);
const hazardTile4 = new THREE.Mesh(boxGeo, warnMat);
hazardTile4.name = 'hazardTile';
hazardTile4.position.set(0.45, 0.22, 0);
hazardTile4.rotation.set(0, deg(90), 0);
pedestal.add(hazardTile4);
const hazardTile5 = new THREE.Mesh(boxGeo, darkMat);
hazardTile5.name = 'hazardTile';
hazardTile5.position.set(0.3897, 0.22, -0.225);
hazardTile5.rotation.set(0, deg(120), 0);
pedestal.add(hazardTile5);
const hazardTile6 = new THREE.Mesh(boxGeo, warnMat);
hazardTile6.name = 'hazardTile';
hazardTile6.position.set(0.225, 0.22, -0.3897);
hazardTile6.rotation.set(0, deg(150), 0);
pedestal.add(hazardTile6);
const hazardTile7 = new THREE.Mesh(boxGeo, darkMat);
hazardTile7.name = 'hazardTile';
hazardTile7.position.set(0, 0.22, -0.45);
hazardTile7.rotation.set(0, deg(180), 0);
pedestal.add(hazardTile7);
const hazardTile8 = new THREE.Mesh(boxGeo, warnMat);
hazardTile8.name = 'hazardTile';
hazardTile8.position.set(-0.225, 0.22, -0.3897);
hazardTile8.rotation.set(0, deg(210), 0);
pedestal.add(hazardTile8);
const hazardTile9 = new THREE.Mesh(boxGeo, darkMat);
hazardTile9.name = 'hazardTile';
hazardTile9.position.set(-0.3897, 0.22, -0.225);
hazardTile9.rotation.set(0, deg(240), 0);
pedestal.add(hazardTile9);
const hazardTile10 = new THREE.Mesh(boxGeo, warnMat);
hazardTile10.name = 'hazardTile';
hazardTile10.position.set(-0.45, 0.22, 0);
hazardTile10.rotation.set(0, deg(270), 0);
pedestal.add(hazardTile10);
const hazardTile11 = new THREE.Mesh(boxGeo, darkMat);
hazardTile11.name = 'hazardTile';
hazardTile11.position.set(-0.3897, 0.22, 0.225);
hazardTile11.rotation.set(0, deg(300), 0);
pedestal.add(hazardTile11);
const hazardTile12 = new THREE.Mesh(boxGeo, warnMat);
hazardTile12.name = 'hazardTile';
hazardTile12.position.set(-0.225, 0.22, 0.3897);
hazardTile12.rotation.set(0, deg(330), 0);
pedestal.add(hazardTile12);
const base = new THREE.Group();
base.name = 'base';
base.position.set(0, 0.36, 0);
base.rotation.set(0, deg(-50), 0);
root.add(base);
const turntable = new THREE.Mesh(new THREE.CylinderGeometry(0.4, 0.42, 0.22, 14), bodyMat);
turntable.name = 'turntable';
turntable.position.set(0, 0.11, 0);
base.add(turntable);
const turntableRing = new THREE.Mesh(new THREE.CylinderGeometry(0.36, 0.36, 0.04, 14), darkMat);
turntableRing.name = 'turntableRing';
turntableRing.position.set(0, 0.24, 0);
base.add(turntableRing);
const yokePlate = new THREE.Mesh(boxGeo2, bodyMat);
yokePlate.name = 'yokePlate';
yokePlate.position.set(0.26, 0.51, 0.14);
base.add(yokePlate);
const yokePlate2 = new THREE.Mesh(boxGeo2, bodyMat);
yokePlate2.name = 'yokePlate';
yokePlate2.position.set(-0.26, 0.51, 0.14);
base.add(yokePlate2);
const baseMotor = new THREE.Mesh(new THREE.BoxGeometry(0.32, 0.36, 0.36), darkMat);
baseMotor.name = 'baseMotor';
baseMotor.position.set(0, 0.38, -0.22);
base.add(baseMotor);
const statusLight = new THREE.Mesh(new THREE.SphereGeometry(0.04, 6, 4), glowMat);
statusLight.name = 'statusLight';
statusLight.position.set(0.17, 0.48, -0.22);
base.add(statusLight);
const shoulder = new THREE.Group();
shoulder.name = 'shoulder';
shoulder.position.set(0, 0.52, 0.14);
shoulder.rotation.set(deg(20), 0, 0);
base.add(shoulder);
const shoulderJoint = new THREE.Mesh(new THREE.CylinderGeometry(0.2, 0.2, 0.5, 12), darkMat);
shoulderJoint.name = 'shoulderJoint';
shoulderJoint.rotation.set(0, 0, deg(90));
shoulder.add(shoulderJoint);
const shoulderCap = new THREE.Mesh(new THREE.CylinderGeometry(0.14, 0.14, 0.7, 10), metalMat);
shoulderCap.name = 'shoulderCap';
shoulderCap.rotation.set(0, 0, deg(90));
shoulder.add(shoulderCap);
const upperArm = new THREE.Mesh(new THREE.BoxGeometry(0.3, 1, 0.34), bodyMat);
upperArm.name = 'upperArm';
upperArm.position.set(0, 0.55, 0);
shoulder.add(upperArm);
const upperArmPanel = new THREE.Mesh(new THREE.BoxGeometry(0.32, 0.5, 0.06), darkMat);
upperArmPanel.name = 'upperArmPanel';
upperArmPanel.position.set(0, 0.495, 0.18);
shoulder.add(upperArmPanel);
const shoulderMotor = new THREE.Mesh(new THREE.CylinderGeometry(0.13, 0.13, 0.42, 10), darkMat);
shoulderMotor.name = 'shoulderMotor';
shoulderMotor.position.set(0, 0.05, -0.2);
shoulderMotor.rotation.set(0, 0, deg(90));
shoulder.add(shoulderMotor);
const cableHose = new THREE.Mesh(tube([[0.18, 0.15, -0.12], [0.24, 0.55, -0.18], [0.18, 0.98, -0.12]], 0.035, 8, 5), darkMat);
cableHose.name = 'cableHose';
shoulder.add(cableHose);
const elbow = new THREE.Group();
elbow.name = 'elbow';
elbow.position.set(0, 1.1, 0);
elbow.rotation.set(deg(95), 0, 0);
shoulder.add(elbow);
const elbowJoint = new THREE.Mesh(new THREE.CylinderGeometry(0.16, 0.16, 0.42, 12), darkMat);
elbowJoint.name = 'elbowJoint';
elbowJoint.rotation.set(0, 0, deg(90));
elbow.add(elbowJoint);
const elbowCap = new THREE.Mesh(new THREE.CylinderGeometry(0.11, 0.11, 0.46, 10), metalMat);
elbowCap.name = 'elbowCap';
elbowCap.rotation.set(0, 0, deg(90));
elbow.add(elbowCap);
const elbowHousing = new THREE.Mesh(new THREE.BoxGeometry(0.26, 0.3, 0.32), bodyMat);
elbowHousing.name = 'elbowHousing';
elbowHousing.position.set(0, -0.12, 0);
elbow.add(elbowHousing);
const counterweight = new THREE.Mesh(new THREE.BoxGeometry(0.22, 0.32, 0.3), darkMat);
counterweight.name = 'counterweight';
counterweight.position.set(0, -0.3, 0);
elbow.add(counterweight);
const forearm = new THREE.Mesh(new THREE.CylinderGeometry(0.11, 0.14, 0.85, 10), bodyMat);
forearm.name = 'forearm';
forearm.position.set(0, 0.5, 0);
elbow.add(forearm);
const forearmBand = new THREE.Mesh(new THREE.BoxGeometry(0.24, 0.05, 0.3), warnMat);
forearmBand.name = 'forearmBand';
forearmBand.position.set(0, 0.62, 0);
elbow.add(forearmBand);
const wrist = new THREE.Group();
wrist.name = 'wrist';
wrist.position.set(0, 1, 0);
wrist.rotation.set(deg(65), 0, 0);
elbow.add(wrist);
const wristJoint = new THREE.Mesh(new THREE.CylinderGeometry(0.1, 0.1, 0.26, 10), darkMat);
wristJoint.name = 'wristJoint';
wristJoint.rotation.set(0, 0, deg(90));
wrist.add(wristJoint);
const wristBody = new THREE.Mesh(new THREE.CylinderGeometry(0.09, 0.08, 0.16, 10), bodyMat);
wristBody.name = 'wristBody';
wristBody.position.set(0, 0.14, 0);
wrist.add(wristBody);
const toolFlange = new THREE.Mesh(new THREE.CylinderGeometry(0.11, 0.11, 0.04, 12), metalMat);
toolFlange.name = 'toolFlange';
toolFlange.position.set(0, 0.24, 0);
wrist.add(toolFlange);
const gripper = new THREE.Group();
gripper.name = 'gripper';
gripper.position.set(0, 0.26, 0);
wrist.add(gripper);
const palm = new THREE.Mesh(new THREE.BoxGeometry(0.3, 0.08, 0.14), darkMat);
palm.name = 'palm';
palm.position.set(0, 0.04, 0);
gripper.add(palm);
const fingerL = new THREE.Group();
fingerL.name = 'fingerL';
fingerL.position.set(0.09, 0.08, 0);
gripper.add(fingerL);
const finger = new THREE.Mesh(boxGeo3, metalMat);
finger.name = 'finger';
finger.position.set(0, 0.1, 0);
fingerL.add(finger);
const fingerPad = new THREE.Mesh(boxGeo4, darkMat);
fingerPad.name = 'fingerPad';
fingerPad.position.set(-0.035, 0.12, 0);
fingerL.add(fingerPad);
const fingerR = new THREE.Group();
fingerR.name = 'fingerR';
fingerR.position.set(-0.09, 0.08, 0);
gripper.add(fingerR);
const finger2 = new THREE.Mesh(boxGeo3, metalMat);
finger2.name = 'finger';
finger2.position.set(0, 0.1, 0);
fingerR.add(finger2);
const fingerPad2 = new THREE.Mesh(boxGeo4, darkMat);
fingerPad2.name = 'fingerPad';
fingerPad2.position.set(0.035, 0.12, 0);
fingerR.add(fingerPad2);
root.traverse((o) => {
if (o.isMesh) {
o.castShadow = true;
o.receiveShadow = true;
}
});
return root;
}
export default createRobotArm;
```
---
Codels — 3D models as code for three.js. Search more: https://codels.download/api/v1/models?q= · Guide: https://codels.download/llms.txt